Krzysztof Walas
Krzysztof Walas, PhD · CTO at Lute

Physical AI that leaves the lab.

Krzysztof Walas is Chief Technology Officer at Lute, building mobile robots that learn physical work from human demonstrations and take it into real factories, warehouses and shop floors. Nearly two decades of research into how machines perceive contact — how a foot reads the ground, how a gripper feels what it holds — now pointed at a harder test than a benchmark: doing useful work in buildings full of people. He remains an Assistant Professor at Poznan University of Technology.

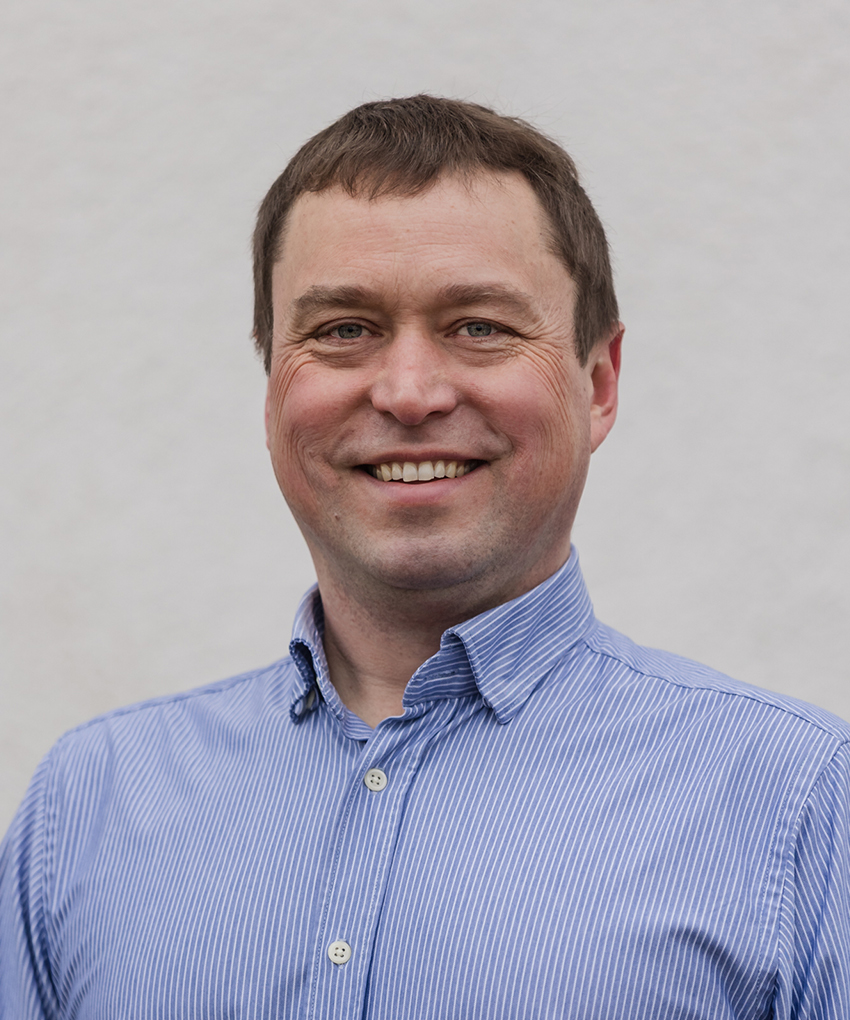
Portrait of Krzysztof Walas
Krzysztof Walas

Synthetic foot-force trace of a walking robot crossing three terrains — the kind of signal a legged robot can use to tell surfaces apart by touch. stance phases shaded

Lute · since 2026

Chief Technology Officer, Lute — physical AI for mobile manipulation; Redwood City & Warsaw

Poznań · now

Assistant Professor, Institute of Robotics and Machine Intelligence, Poznan University of Technology

Adra · since June 2024

Board of Directors, Adra — the AI, Data and Robotics Association (robotics, research community)

ELLIS · since Feb 2024

Member of the ELLIS Society, the European Laboratory for Learning and Intelligent Systems

Lute

Physical AI in production. Company site at lute.one.

Lute builds mobile robots that learn from human demonstrations, aimed at the work that is going undone because there is nobody to do it. As CTO, Krzysztof Walas owns the technical direction: the robots, the data pipeline that teaches them, and everything it takes to run a fleet in someone else's building rather than in a laboratory. The company works out of Redwood City, California and Warsaw, Poland.

Learning from human demonstrations

Policies are learned from curated teleoperated demonstrations and improve as more arrive. The hard part is not collecting data but knowing which of it is worth training on — a reward model and temporal-progress estimates rank trajectories by quality across different robots and different operators.

imitation learning · data curation · fleet learning

Order picking on a live shop floor

A retail deployment picking against a catalogue of more than 40,000 SKUs while the shop is open, working around staff and customers. Orders arrive from the customer's own systems; the robot localises, plans, avoids obstacles, recovers from its own failures and gets to the drop-off point.

mobile manipulation · retail · autonomy in the wild

Assembly that punishes imprecision

Factory subtasks with no tolerance for a near miss — threading a wire inside a fibre-reinforced polymer tube to sub-millimetre accuracy, for instance. These are where general-purpose policies still break, and where the distance between a convincing demo and a production cell has to be measured honestly.

precision manipulation · manufacturing · evaluation

OpenGVL — measuring data quality

An open benchmark for estimating how far a trajectory has progressed toward its goal, across both robot and human demonstrations, using vision-language models. It exists so dataset curation can be automated and audited instead of done by eye. arXiv:2509.17321

benchmark · VLMs · open research

The thread running back to the academic work is unchanged: a robot that can feel what it is doing fails more gracefully than one that can only look at it. What changed is the bar. A deployed system has to work on a Tuesday afternoon, in a building full of people, without anyone standing by to reset it.

Research

The groundwork the product stands on — perception applied to two kinds of contact, walking and grasping. Team page at PUT robotics.

Haptic terrain perception for legged robots

Force and torque signals from a robot's feet carry enough information to recognise the ground it is standing on. The team's transformer- and state-space-based classifiers (HAPTR, HAPTR2, HAPmamba) are small and fast enough to run on board and are benchmarked on public datasets such as PUTany and QCAT.

legged robots · time-series learning · ANYmal

Sensing physical parameters through interaction

Stiffness, damping and friction are hard to see but easy to feel. This line of work estimates such parameters from direct contact — for example regressing an object's stiffness from inertial sensors on the fingers of a soft gripper — and asks how far vision alone can get.

soft grippers · IMUs · parameter estimation

Manipulating deformable linear objects

Cables, wires and hoses change shape as you handle them. Model-based methods that estimate the object's parameters online, and calibration-free bimanual control, make routing and fitting tasks feasible for dual-arm robots in manufacturing — work that started in the REMODEL project.

deformable objects · bimanual · industrial robotics

Learning agile legged locomotion with active perception

Quadrupeds that switch between gaits, use whole-body contact and an actuated spine, and sense the world through their actuators rather than only through cameras. This is the focus of INTENTION, a joint project with the Intelligent Autonomous Systems group at TU Darmstadt.

reinforcement learning · actuated spine · proprioception

Much of this work leaves the lab: legged robots inspecting mines and sewers in the THING project, a quadruped taken into an ice cave, and LunarLeaper, a mission concept for exploring the lunar subsurface with a small legged robot.
Projects

Grants where he is or was principal investigator on the Poznan side.

  • ongoing

    INTENTIONlearnINg versaTile lEgged locomotioN wiTh actIve perceptiON — agile quadruped locomotion with non-visual sensing and a flexible spine, together with Jan Peters' group at TU Darmstadt.

    NCN–DFG grant
    PI at PUT
  • 2019 – 2023

    REMODELRobotic tEchnologies for the Manipulation of cOmplex DeformablE Linear objects — dual-arm handling of wires and cables in manufacturing, coordinated by the University of Bologna with partners including Volkswagen Poznań.

    Horizon 2020
    PI at PUT
  • 2018 – 2021

    THINGsubTerranean Haptic INvestiGator — haptic perception and active exploration for legged robots, tested in mines and sewers with the ANYmal quadruped.

    Horizon 2020
    PI at PUT
  • 2017 – 2020

    Perception and control for robotic manipulation of elastic objectsLIDER programme grant from Poland's National Centre for Research and Development.

    NCBR LIDER
    PI

Selected publications

Full list on Google Scholar and ORCID.

  1. 2026

    Evaluation of an Actuated Spine in Agile Quadruped Locomotion

    N. Bohlinger, P. Kicki, D. Tateo et al., with J. Peters and K. Walas

    Preprint

  2. 2025

    LunarLeaper — A mission concept to explore the lunar subsurface with a small-scale legged robot

    H. Kolvenbach, A. Mittelholz, S. C. Stähler, P. Arm, V. T. Bickel, … K. Walas, … M. Hutter

    Acta Astronautica 240, 63–75

  3. 2024

    Legged robots beyond bioinspiration

    K. Walas

    Science Robotics 9(89), eadp1956 · doi:10.1126/scirobotics.adp1956

  4. 2024

    Deformable Linear Objects Manipulation With Online Model Parameters Estimation

    A. Caporali, P. Kicki, K. Galassi, R. Zanella, K. Walas, G. Palli

    IEEE Robotics and Automation Letters 9(3), 2598–2605

  5. 2024

    Calibrationless Bimanual Deformable Linear Object Manipulation With Recursive Least Squares Filter

    A. Szymko, P. Kicki, K. Walas

    IEEE Access 12, 126707–126716

  6. 2024
  7. 2022

    HAPTR2: Improved Haptic Transformer for legged robots' terrain classification

    M. Bednarek, M. R. Nowicki, K. Walas

    Robotics and Autonomous Systems 158, 104236 · doi:10.1016/j.robot.2022.104236

  8. 2021

    Fast haptic terrain classification for legged robots using transformer

    M. Bednarek, M. Łysakowski, J. Bednarek, M. R. Nowicki, K. Walas

    European Conference on Mobile Robots (ECMR)

  9. 2021
  10. 2019

    What am I touching? Learning to classify terrain via haptic sensing

    J. Bednarek, M. Bednarek, L. Wellhausen, M. Hutter, K. Walas

    IEEE International Conference on Robotics and Automation (ICRA), 7187–7193

  11. 2019

    Robotic Touch: Classification of Materials for Manipulation and Walking

    J. Bednarek, M. Bednarek, P. Kicki, K. Walas

    IEEE International Conference on Soft Robotics (RoboSoft), 527–533

Bio

From hexapods in Poznań to robots on a live shop floor.

Krzysztof Walas graduated from Poznan University of Technology with an MSc in Automatic Control and Robotics and received his PhD in Robotics there in 2012, with honours, for a thesis on legged-robot locomotion in structured environments — work that grew up alongside the university's Messor walking robots. He then joined the Intelligent Robotics Laboratory at the University of Birmingham's School of Computer Science as a postdoctoral researcher, working on object categorisation and pose estimation from 3D data, before returning to Poznań to lead the Perception for Physical Interaction team. In 2023 he took on a research team lead role at IDEAS NCBR in Warsaw, and in 2026 moved into industry as Chief Technology Officer of Lute — carrying the same question about contact and physical understanding out of the laboratory and into systems that have to earn their keep.

  • 2007 – 2012

    Research and teaching assistantInstitute of Control and Information Engineering, Poznan University of Technology

  • 2012

    PhD in Robotics, with honoursPoznan University of Technology — legged-robot locomotion in structured environments

  • 2014

    Postdoctoral research associateIntelligent Robotics Lab, School of Computer Science, University of Birmingham

  • 2017

    LIDER grantNational Centre for Research and Development (NCBR), Poland

  • 2018 – 2023

    Principal investigator at PUT in two Horizon 2020 projectsTHING (subterranean legged locomotion) and REMODEL (deformable-object manipulation)

  • 2023 – 2026

    Research team lead, Physical Interaction RoboticsIDEAS NCBR and the IDEAS Research Institute, Warsaw

  • 2024

    ELLIS Society member · Science Robotics author · Adra Board of DirectorsElected to Adra's board in the robotics section on behalf of the research community — the first board member from Poland

  • 2026

    Chief Technology Officer, LutePhysical AI for mobile manipulation — robots that learn physical work from human demonstrations

  • now

    CTO at Lute · Assistant Professor, PUTLute, Redwood City and Warsaw, and the Institute of Robotics and Machine Intelligence, Poznań

Contact

Students, collaborators and partners — best reached through the profiles below.

Profiles